Español
 Italiano
 Deutsch
 Français
 Português
 العربية
 Türkçe
 Русский
 Tiếng Việt
 한국어
 日本語
 简体中文
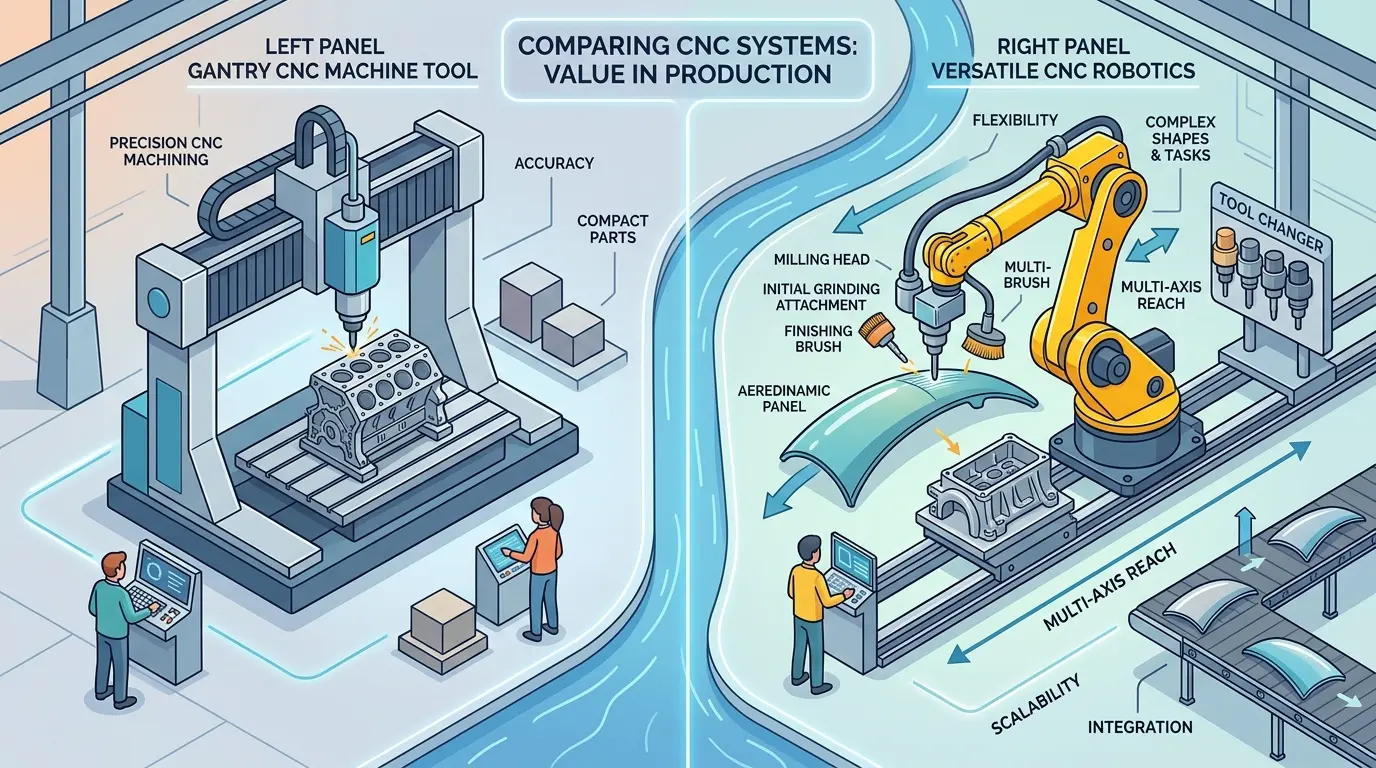
Define the workload before judging robot arms against CNC machine tools, audit your cell for lost minutes rather than technology categories. The recurring failure in factory automation is treating robots as replacements for machining capability when they actually protect machine-tool time or remove manual handling between stable process steps. If your spindle idles while operators load blanks, or skilled machinists spend shifts on material transfer, robotics deserves serious evaluation. But if chatter, tolerance drift, or unstable fixturing is the real loss, no robot will rescue that process. Stable cutting comes first; surrounding automation second.
Start With Lost Minutes, Not Technology Categories
The recurring mistake in factory automation planning is treating robots and CNC machine tools as competing answers to the same production problem. They are not. A CNC machine tool is engineered to hold a controlled cutting process under load. A robot is engineered to move, orient, transfer, and repeat motion across space. The two become productive together only when the plant assigns them different jobs inside the same cell.
The practical question is not “robot or machine tool?” It is “which part of this cell is actually losing money?” Once that is answered, the role split becomes visible.
In most operating plants, robots do not replace machine tools. They either protect machine-tool time or remove manual handling between stable process steps. When buyers lose sight of that, they end up asking robotics to solve a machining problem, or asking a machine tool to absorb labor waste that belongs outside the cut.
Audit the Cell Before You Choose the Technology
The fastest way to clarify robot value is to stop comparing product categories and start measuring lost minutes. Walk the cell and ask where productive time is actually disappearing.
Is the machine sitting idle while operators load and unload blanks? Is finished work staying in the spindle too long after cycle end? Are transfers between machining, washing, deburring, inspection, or staging still manual and inconsistent? Or is the real loss still happening at the cut itself through chatter, unstable fixturing, tool-life problems, or tolerance drift?
That distinction matters because robots solve movement waste far better than they solve process instability. If the lost minutes are outside the cutting event, robotics deserves serious attention. If the lost minutes are inside the cutting event, the plant has a machine-tool or process-control problem first, and no amount of handling automation will fix it.
Machine Tools Own Force, Geometry, and Process Truth
When the core challenge is controlled cutting, geometric accuracy, repeatable tolerance, or process rigidity, the CNC machine tool remains the primary answer. Milling, turning, boring, drilling, grinding, and routing depend on a structure built for real material removal under load. That is what the machine tool is for.
This is where automation projects go wrong. The plant sees labor pressure or underwhelming output and starts looking at robotics because automation feels like progress. But if the cutting process itself is unstable, no robot will rescue the result. A robot can load a poor process more efficiently, but it cannot make that poor process accurate.
The rule still holds: stable process first, surrounding automation second. The machine tool must already deserve higher utilization before the factory spends money protecting that utilization.
Robots Create Value in the Minutes Before and After the Cut
Robotics becomes commercially interesting when the machine tool is fundamentally sound but too much productive time is lost around it. If the spindle waits on people, if the operator spends excessive time on repetitive presentation work, or if machine-to-machine transfers are swallowing skilled labor, then the robot may improve output without changing the machining process itself.
This is the most practical way to understand robot value. Robots create margin in non-cut time. They protect the expensive minutes around the machine rather than replacing the machine’s core function.
That sounds narrow, but in many real cells those lost minutes are exactly where output is disappearing.
Loading and Unloading Are the First Honest Robot Use Cases
Machine tending remains one of the clearest robot applications because the value is easy to quantify. If the machine cycle is stable and the part family is consistent enough, the robot can keep blanks flowing in and finished parts flowing out with far less variability than a manually interrupted routine.
This matters most where:
- Cycle time is long enough for tending to matter.
- Operators are being pulled away by other tasks.
- The part family is stable enough to justify repeat motion.
- Spindle idle time is visibly higher than management expects.
In those cells, the robot is not competing with the machine tool. It is protecting the machine tool from preventable waiting.
Transfer Between Process Steps Is the Second Strong Use Case
Many factories look at robotics only at the machine door and miss a second major value area: transfers between process steps. Parts that leave machining often need washing, deburring, inspection, marking, staging, or an oriented handoff before the next operation begins. When these transitions are still manual, inconsistency and delay accumulate quietly.
Robots can help here by standardizing presentation, reducing repetitive lifting or reorientation, and making it easier for downstream automation or inspection routines to work consistently. In those cases, the robot is not increasing spindle utilization directly. It is removing handling waste between known stations.
That can still be commercially important, especially in cells where manual transfer work is consuming higher-skill labor than the task deserves.
Remove Human Repetition, Not Human Judgment
One of the most useful buying questions is whether people in the current cell are doing repetitive movement or high-value judgment. If the current labor burden is mostly loading, unloading, rotating, staging, or transporting, robotics deserves stronger consideration. If the burden is still setup interpretation, process correction, feature verification, or quality response, then the robot may be arriving too early.
Good automation does not try to eliminate the best human work first. It strips away the repetitive motion that prevents skilled people from spending time on setup quality, process improvement, inspection response, or production control.
That is usually where the labor case becomes clearer. The issue is not simply whether labor is expensive. It is whether valuable labor is trapped in low-value repetition.
High-Mix Cells Need a Different Robot Justification
Robot value changes with order pattern. In repeat-volume cells, a relatively stable tending routine may already justify the investment because the motion logic changes little and the return can be explained through utilization. In high-mix environments, the robot has to earn its place differently.
The questions become harder:
- Can fixtures and presentation methods stay disciplined across changing jobs?
- Will grippers, sensors, and part orientation logic remain useful when parts vary?
- Can the robot keep contributing when programs and setups change often?
- Is the plant organized enough to prevent automation from collapsing under variation?
That does not mean robotics is wrong for high mix. It means the cell design burden rises, and the justification must be more disciplined. Repeat work rewards the robot with stability. High-mix work demands more from the integration strategy.
Cell Design Matters More Than the Robot Arm
Buyers naturally focus on the robot arm because it is the visible technology. In practice, robot success depends more on everything around the arm: grippers, part presentation, infeed logic, orientation consistency, chip management, queue design, safety layout, and the way the robot exchanges signals with the machine tool and nearby stations.
Robotic integration should be judged as a cell design problem rather than an arm purchase. The arm may be capable on paper and still underperform if the parts arrive inconsistently, if the buffer logic is weak, or if the surrounding process keeps producing exceptions the automation was never designed to absorb.
This is why many disappointing robot projects are not really robot failures. They are cell-design failures wearing a robot label.
Robots Are Weak Answers to Core Machining Instability
Robotics is a weak answer when the real issue is poor machining capability, weak fixturing, chatter, bad tool-life control, unstable tolerances, or part programs that still need frequent manual rescue. A robot cannot make a drifting process mature. It can only feed or move that drifting process more consistently.
Factories should audit the cut before they automate around the cut. If the machine still needs operator judgment just to stay inside tolerance, the robot is almost certainly being asked to solve the wrong problem.
This is often the most important disqualifier in the entire decision.
Build the ROI Case Around Protected Machine Time or Removed Handling Waste
Good robot investments justify themselves in one of two ways. Either they protect expensive machine time by reducing idle minutes, or they remove repetitive handling burden between stable process steps. Weak robot investments rely on vague language about modernization, lights-out ambition, or future readiness without naming the actual loss the robot will remove.
The return case should be explicit. Measure spindle idle time. Measure queue delays. Measure the labor consumed by presentation, transfer, or unloading. Measure where operators are trapped in repetition. If those losses are real and recurring, the robot conversation becomes grounded. If they are not measurable, the project is probably being sold too abstractly.
Read Automation Quotes as Workflow Proposals
Automation proposals often look clean because they describe ideal motion. Real factories do not run on ideal motion. Parts arrive slightly differently. Buffers fill. Chips interfere. Blank quality drifts. Changeovers take longer than the demo implied. Operators work around exceptions in ways the presentation never mentioned.
That is why automation quotes should be read as workflow proposals rather than as hardware offers. Compare machinery and automation quotes line by line so integration scope, safety assumptions, exception handling, and changeover responsibility are visible. For factories thinking about automation more broadly, the wider logic in how CNC automation improves accuracy, throughput, and repeatability is usually more useful than treating a robot as a standalone trend. At management level, what makes industrial CNC equipment worth the investment remains the better capital framing.
The Best Robot Decision Ends With a Clear Division of Labor
The practical conclusion is straightforward. The CNC machine tool should keep ownership of cutting under force, process stability, and geometric truth. The robot should earn its place by protecting machine time or reducing repetitive handling between stable steps. When the division of labor is clear, the technologies complement each other well. When it is not, factories usually automate the wrong task and then blame the robot for a decision problem upstream.
Robotics adds value where motion is the bottleneck, where repetition is consuming skilled labor, and where the core machining process is already good enough to deserve higher utilization. That is where the investment becomes real instead of fashionable.
Practical Examples of Where the Split Works
Consider a typical mid-size job shop running a vertical machining center with a 12-minute cycle. The operator loads a blank, starts the cycle, and then walks to another machine to deburr parts from the previous run. If the operator is away for six minutes of that 12-minute cycle, the spindle sits idle for half its available time. A robot that can load and unload in under two minutes recovers those six minutes per cycle. Over a two-shift day, that is roughly two hours of additional cutting time per machine. The machine tool’s capability did not change. The robot simply stopped the spindle from waiting on a person.
Another example: a cell producing housings that require milling, then washing, then deburring, then inspection. The milling machine finishes a part and the operator carries it to the wash station, then to the deburr bench, then to the inspection table. Each transfer takes three to five minutes and introduces orientation errors. A robot that moves the part through those stations in a fixed sequence eliminates the variability and frees the operator to handle setup changes and quality checks. The machining process is untouched, but the throughput of the whole cell improves because the part flow is no longer dependent on a person’s availability.
When the Robot Should Not Be Considered
There are cells where robotics is the wrong answer regardless of how attractive the labor savings look. If the machine tool is producing parts with tolerance drift that requires an operator to adjust offsets mid-run, the robot will simply feed more bad parts before the drift is caught. If fixturing is inconsistent and parts seat differently each time, the robot will present misaligned blanks to the spindle and the machine will cut scrap. If tool life is unpredictable and tools break without warning, the robot cannot detect the failure fast enough to prevent damage.
In those situations, the plant should invest in process stabilization first. That might mean better tooling, more rigid fixturing, improved coolant delivery, or a more capable machine tool. Once the process holds tolerance without constant intervention, the robot becomes a viable addition. Automating an unstable process multiplies the cost of instability because the robot runs unattended and the scrap accumulates faster.
Quantifying the Labor Trap
The labor case for robotics is often misstated. The issue is rarely that labor is too expensive in absolute terms. It is that skilled labor is being consumed by tasks that do not require skill. A machinist earning a premium wage who spends 40 percent of the shift loading blanks and moving parts is not being paid to think. The plant is paying machinist wages for material-handling work.
A robot that takes over the handling portion allows that machinist to focus on setup verification, first-article inspection, tool monitoring, and process improvement. The economic gain is not just the labor hours recovered. It is the improvement in process quality that comes from having a skilled person actually doing skilled work. That is harder to put on a spreadsheet, but it is often the difference between a cell that runs and a cell that improves.
Changeover Discipline and Robot Viability
One of the most overlooked factors in robot viability is changeover discipline. A robot can handle a stable part family with minimal reprogramming. But if the cell changes over frequently and the changeover process is not documented, the robot will spend more time waiting for new programs and gripper changes than it saves in tending.
Plants that succeed with robots in high-mix environments usually have a formal changeover procedure. They use quick-change grippers, standardized pallets, and pre-verified programs. They also have a clear owner for the changeover process. Without that discipline, the robot becomes an expensive piece of equipment that runs only when the stars align.
Safety Layout and Human Collaboration
The physical layout of the cell determines whether a robot can work safely alongside people. If the robot operates in a fully enclosed cell, the safety design is simpler. If the robot shares space with operators who need to access the machine for setup or inspection, the plant needs light curtains, safety scanners, or interlocked fencing.
These safety components add cost and complexity, and they affect cycle time. A robot that must slow down or stop when a person enters the zone may not deliver the throughput gains the plant expects. The layout should be designed so that the robot’s work envelope does not overlap with the operator’s access path unless the safety system is explicitly engineered for that interaction.
Signal Exchange and Integration Depth
The robot and the machine tool must communicate reliably. That means more than a simple start/stop signal. The robot needs to know when the machine has finished its cycle, when the door is open, when the spindle has stopped, and when the fixture is clear. The machine needs to know when the robot has placed the part, when the gripper has released, and when it is safe to close the door and start the next cycle.
This signal exchange is where many integrations fail. If the handshake is not robust, the cell stops for reasons that are hard to diagnose. The robot appears to be the problem, but the real issue is incomplete or poorly implemented communication logic. Plants should insist on a detailed signal map before approving an integration proposal.
Maintenance and Ownership
A robot adds a maintenance burden that the plant may not have anticipated. The robot has its own controller, servos, gearboxes, and safety systems. It needs regular inspection, lubrication, and occasional recalibration. If the plant does not have personnel trained on the robot, it will depend on the integrator for service, which adds cost and downtime risk.
The ownership question matters as much as the purchase price. Who will maintain the robot? Who will update the programs when parts change? Who will troubleshoot the signal exchange when the cell stops? If the answers are not clear, the robot will become a source of friction rather than a source of output.
Comparing Quotes With the Workflow in Mind
When evaluating automation proposals, the plant should compare them as workflow descriptions. Each proposal should state what happens when a part arrives, how it is presented, how the robot grips it, how it is loaded, how the machine signals completion, how the finished part is removed, and where it goes next. If the proposal does not describe these steps, it is incomplete.
The plant should also ask about exception handling. What happens when a part is out of tolerance? What happens when the gripper fails to pick? What happens when the buffer is full? Proposals that ignore these scenarios are not ready for a real factory floor.
The Capital Decision in Context
For plants that are also evaluating new machine tools, the robot decision should not be made in isolation. The machine tool and the robot are part of the same cell. The machine tool determines the process capability. The robot determines the utilization of that capability. Both investments should be evaluated together, with the process stability question answered first.
If the existing machine tool is capable and underutilized, the robot is the higher-value investment. If the existing machine tool is struggling to hold tolerance, the machine tool is the higher-value investment. The order of investment matters more than the technology choice.
Approve Automation After the Process Is Stable
Before approving a robot, record where the spindle waits, how often operators leave the cell, and which transfers create avoidable handling. Those observations show whether the next investment should protect machine time or improve the cutting process itself.
If the machine tool already holds the required process window and manual movement is the constraint, automation can earn its place. If the process still suffers from chatter, unstable fixturing, or tolerance drift, fix that condition first and revisit the robot after the machine is producing reliable parts.